Chuanbeibei Shi
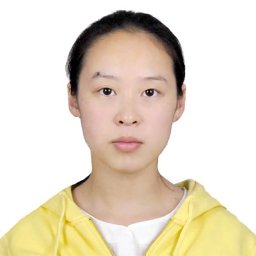
Portrait of Chuanbeibei Shi

Chuanbeibei Shi

Ph.D. Student · Telecommunications Lab, Saarland University

Saarbrücken, Germany shi [at] nt.uni-saarland.de

I am a Ph.D. student at the Telecommunications Lab of Saarland University, which I joined in February 2025. My Ph.D. is funded by the Saarland/Intel Joint Program on the Future of Graphics and Media. I work on 3D computer vision for next-generation visual media within the FROST project: light-field scene representations, light-field rendering and multi-view depth estimation.

My background combines computer vision and robotics, with a focus on multi-modal 3D perception and RGB–depth sensor fusion: fusing LiDAR point clouds with camera images for object detection, RGB-D fusion for autonomous drone perching, active vision under limited fields of view, and visual-inertial state estimation for multi-robot aerial systems.

I received my M.Sc. in Robotics from the University of Bristol in 2024 and my B.Sc. in Robotics from Beijing Institute of Technology in 2022, with a Distinguished Bachelor's Thesis on LiDAR–camera active vision, supervised by Prof. Yushu Yu, Prof. Vincenzo Lippiello and Dr. Mauro Bellone.

  • 3D computer vision
  • Depth estimation
  • RGB–depth sensor fusion
  • Light fields & rendering
  • 3D scene representations
  • Robot perception

News

Older news
  • May 2024 Attending ICRA 2024 in Yokohama, Japan, with three of our papers presented in oral sessions: Aerial Systems: Perception and Autonomy I, Aerial Systems: Mechanics and Control III and Multi-Robot SLAM.
  • Jan 2024 Our paper Tight Fusion of Odometry and Kinematic Constraints for Multiple Aerial Vehicles in Physical Interconnection was accepted to ICRA 2024.
  • Sep 2023 I started my M.Sc. in Robotics at the University of Bristol, with access to the Bristol Robotics Laboratory, one of the UK’s leading centres for robotics research.
  • Aug 2023 Our work on real-time multi-modal active vision for object detection on UAVs was accepted to IEEE Robotics and Automation Letters.

Education

  1. Ph.D. Student

    Feb 2025 – Present

    Saarland University · Telecommunications Lab · Saarbrücken, Germany

    • Advisor: Prof. Thorsten Herfet
    • Research on light-field scene representations, multi-view depth estimation and light-field rendering within the FROST project.
  2. M.Sc. in Robotics

    Sep 2023 – Sep 2024

    University of Bristol · Bristol, UK

    • Thesis: Bio-inspired active motion and sensor fusion for uncrewed air vehicle environmental monitoring
    • Advisors: Prof. Shane Windsor and Dr. Bahadir Kocer
  3. B.Sc. in Robotics

    Aug 2018 – Jun 2022

    Beijing Institute of Technology · Beijing, China

    • Distinguished Thesis: Active vision for object detection on UAVs equipped with limited field-of-view LiDAR and camera
    • Advisors: Yushu Yu, Vincenzo Lippiello and Mauro Bellone

Selected Publications

Full list on Google Scholar

2026

  1. CVMP First author

    Froxels for Production: Ray-Level Inspection and Consensus-Guided Light-Field Rendering

    Chuanbeibei Shi, Robin Kremer, Thorsten Herfet

    ACM European Conference on Visual Media Production (CVMP), London, UK, 2026. Accepted

    This work will be presented by my co-authors at CVMP in London. Please feel welcome to reach out to them during the conference.

2024

  1. RA-L

    Multi-Agent Visual-Inertial Localization for Integrated Aerial Systems With Loose Fusion of Odometry and Kinematics

    Ganghua Lai, Chuanbeibei Shi, Kaidi Wang, Yushu Yu, Yiqun Dong, Antonio Franchi

    IEEE Robotics and Automation Letters, vol. 9, no. 7, pp. 6504–6511, 2024.

  2. ICRA

    Tight Fusion of Odometry and Kinematic Constraints for Multiple Aerial Vehicles in Physical Interconnection

    Yingjun Fan, Chuanbeibei Shi, Ganghua Lai, Ruiheng Zhang, Yushu Yu, Fuchun Sun, Yiqun Dong

    IEEE International Conference on Robotics and Automation (ICRA), pp. 3891–3897, 2024.

2023

  1. RA-L First author

    Real-Time Multi-Modal Active Vision for Object Detection on UAVs Equipped With Limited Field of View LiDAR and Camera

    Chuanbeibei Shi, Ganghua Lai, Yushu Yu, Mauro Bellone, Vincenzo Lippiello

    IEEE Robotics and Automation Letters, vol. 8, no. 10, pp. 6571–6578, 2023.

  2. IJRNC First author

    Constrained Control for Systems on Matrix Lie Groups with Uncertainties

    Chuanbeibei Shi, Yushu Yu, Yuwei Ma, Dong Eui Chang

    International Journal of Robust and Nonlinear Control, vol. 33, no. 5, pp. 3285–3311, 2023.

2022

  1. AMM

    A Hierarchical Control Scheme for Multiple Aerial Vehicle Transportation Systems with Uncertainties and State/Input Constraints

    Yushu Yu, Chuanbeibei Shi, Dan Shan, Vincenzo Lippiello, Yi Yang

    Applied Mathematical Modelling, vol. 109, pp. 651–678, 2022.

Projects

2025 · Saarland University

Multi-View Depth Estimation for Planar Light-Field Arrays

Research Immersion Lab project evaluating multi-view depth estimation algorithms on planar light-field camera arrays, as part of the FROST project.
  • Light fields
  • Depth estimation
  • 3D vision

Jul 2021 – Aug 2023 · Beijing Institute of Technology

Active Vision for Object Detection on UAVs with Camera and LiDAR

Turned LiDAR point clouds into multi-channel images and fused them with camera images for CNN object detection. Derived perception constraints that keep the region of interest in both sensors' limited fields of view, built them into a model predictive controller, and flew it on a real small-scale UAV.

  • Active vision
  • LiDAR–camera fusion
  • MPC
  • Deep learning

Jul 2019 – Mar 2021 · Beijing Institute of Technology

Geometric Tube-Based MPC for Aerial Robots

Constrained control for systems on manifolds with uncertainties and input/state constraints, via tube-based MPC on Euclidean space. Proved input-to-state stability and recursive feasibility, and implemented the controller on real aerial robots.

  • Geometric control
  • Tube MPC
  • Lie groups

Dec 2020 – Sep 2021 · Beijing Institute of Technology

Robust Control of Multiple Aerial-Vehicle Transportation Systems

Modelled multi-UAV cooperative transportation systems and designed a hierarchical control scheme that handles uncertainties and state/input constraints, compared against existing controllers in MATLAB simulation.

  • Multi-robot systems
  • Robust control

Sep 2020 – May 2021 · Beijing Institute of Technology

Obstacle-Avoidance Car with Raspberry Pi and Arduino

Real-time YOLOv3 detection of cars and blocks on a Raspberry Pi camera, combined with ultrasonic and infrared sensing and Raspberry Pi-to-Arduino serial motor control for autonomous obstacle avoidance.

  • Embedded vision
  • YOLO
  • Raspberry Pi

Sep 2018 – Oct 2019 · Beijing Institute of Technology

Rotor-Wing Amphibious UAV

Modelled an amphibious quadrotor that keeps a submarine-style hull, with a retractable four-rotor structure for switching between flight and diving, plus onboard sensors and cameras for environmental monitoring.

  • UAV design
  • Modelling

Experience

  1. Research Intern

    Sep 2024 – Dec 2024

    Czech Technical University in Prague · Multi-robot Systems (MRS) Group · Prague, Czech Republic

    • Advisors: Dr. Robert Pěnička and Prof. Martin Saska
    • Developed a perception-aware model predictive control system with integrated LiDAR sensing for autonomous drones.
  2. Graduate Researcher

    Mar 2024 – Sep 2024

    University of Bristol · Bio-Inspired Flight Lab · Bristol, UK

    • Advisors: Prof. Shane Windsor and Dr. Bahadir Kocer
    • Worked on vision-based RGB-D fusion for robust, autonomous drone perching with a tendon-driven mechanism.
    • Designed and built a bio-inspired gripper for the tendon-driven perching mechanism.
    • Supervised a Bachelor’s student in refining the mechanism; the work was published at IROS 2025 (paper).
  3. Autonomous Driving Algorithm Developer (Intern)

    Sep 2022 – Jun 2023

    Megvii Technology · Beijing, China

    • Developed vision algorithms for obstacle detection and tracking based on multi-LiDAR and camera fusion.
    • Helped build simulated driving-test software and ran semi-closed-loop and closed-loop vehicle tests with SUMO–CARLA co-simulation.
  4. Research Assistant, Data Mining and Analysis

    Jul 2021 – Aug 2021

    North Carolina State University · Raleigh, NC, USA

    • Advisor: Muhammad Shahzad
    • Analysed spatiotemporal supply and usage data from 12 dockless e-scooter sharing systems across 11 cities to compare how they are used.
    • Used Python data mining to study differences in urban travel behaviour and the use of micro-mobility platforms.
  5. Research Assistant, Machine Learning & Artificial Intelligence

    Jul 2019 – Aug 2019

    Massachusetts Institute of Technology · Cambridge, MA, USA

    • Studied decision-making and Q-learning in the machine learning and AI summer school.
    • Built a neural network that identifies the artist of a painting from its image.

Service & Honors

Reviewer

  • IEEE Robotics and Automation Letters (RA-L)
  • IEEE Transactions on Automation Science and Engineering (T-ASE)
  • IEEE International Conference on Robotics and Automation (ICRA)
  • IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
  • IEEE International Conference on Intelligent Transportation Systems (ITSC)

Honors & Awards

  • 2022 Distinguished Bachelor's Thesis, School of Mechatronic Engineering, Beijing Institute of Technology